Applications / EV Testing
EV testing with controlled charging conditions
Validate how an electric vehicle (EV) responds during charging. Use a system that acts as its charging station to set the charging communication and the electrical conditions of the configured test setup. Repeat each charging test and check the vehicle’s response against its requirements.
Test scenario: the charging station replies late
Illustrative test: let the simulated charging station delay a supported response. Check whether the vehicle waits, retries or stops as its requirements specify. The EVCC manages the charging conversation, the BMS supplies battery limits, and the OBC converts AC into DC for the battery. Their responses must agree with the measured electrical behaviour.
Decision path
EV charging testing: response to a lower DC current limit
Public chargers and prototype EVSE (electric vehicle supply equipment, or charging station) cannot hold every signal, protocol, power and fault condition constant. A controlled EVSE simulation makes vehicle-side findings reproducible from controller integration to complete-vehicle release.
DC EV test example: vehicle reaction to a lower station current limit
| Test element | Defined condition or observation |
|---|---|
| DUT and simulated partner | A real vehicle is connected to a controlled EVSE simulation. The selected EVCA system, source and interfaces must support the DC protocol and operating point used. |
| Changed condition | The simulated charging station communicates a lower available current during charging. Keep the BMS limits and other controlled conditions constant for the comparison. |
| Expected EV reaction | Check that the EVCC charging request reflects the changed station limit together with the applicable BMS limits, within the response required for the chosen protocol and test case. |
| Evaluation | Correlate the announced EVSE limit, EVCC request, available vehicle-network signals and measured electrical response in comframe. Record the defined acceptance criteria, timing and observed result. |
This is a test objective, not a reported measurement result. Physical current-response testing requires the configured power path and released measurement functions. An EVCC communication bench checks messages and states; it does not establish the complete vehicle’s electrical response.
EVCC–BMS integration testing · EVCA Flex · Analysis layers and released scope
- 01Customer situation
EVCC, BMS (battery management system), OBC and vehicle functions must agree during EV charging.
- 02Usual alternative
Drive to changing infrastructure and infer the cause from one charging pair.
- 03Missing evidence
Controlled boundary states, synchronised layers and repeatable regression.
- 04Controlled method
Simulate the EVSE, define the power boundary and capture vehicle reactions in one timeline.
Application first
EV test scope: EVCC, integrated charging system or complete vehicle
Decide whether to test the charging controller, vehicle subsystem or complete vehicle according to integration maturity and the decision you need to verify.
EVCC and communication
Develop the charging controller and protocol stack on the bench. Verify message content, timing, certificates, low-level states and state-machine behaviour without waiting for the complete vehicle.
Typical path: EVCA ComOnly and comframeEVCC, BMS and OBC integration
Check that charging negotiation, battery permission, onboard conversion, vehicle states, contactors and the high-voltage path produce one consistent vehicle response.
Typical path: EVCA Flex, Battery Cell Simulator (BCS) and comframeComplete vehicle and high power
Validate the real vehicle under controlled AC, DC CCS, CHAdeMO, GB/T DC or MCS conditions. Correlate protocol, signals, voltage, current, safety and thermal reactions.
Typical path: EVCA Flex, Multi Mobile or MCS
One vehicle. Different test objectives at every stage.
EV charging requirements from controller development to vehicle release
As you integrate more of the physical system, keep each original requirement linked to the controlled condition and expected response used to test it.
- 1Component development
EVCC, BMS, OBC and charging-related control functions before the complete vehicle is available.
EVCA ComOnly, BCS, comframe - 2EVCC, BMS and OBC integration stage
Charging requests, battery limits, AC conversion, direct DC charging and vehicle execution on one timeline.
EVCA Flex, BCS, comframe - 3Conformance and robustness
Standards-based behaviour plus boundaries, missing messages, timing changes and deliberately difficult partner behaviour.
EVCA and Test Libraries - 4Vehicle and high-power validation
Complete-vehicle testing across communication, low-level signals, physical power, safety, thermal behaviour and EMC.
EVCA Flex, EVCA MCS, EMC Link - 5Interoperability and field validation
Test the real vehicle with real charging stations and preserve the exact interaction that produced a failure.
EVCA Interop and Multi Mobile - 6Regression, release and production
Use the validated charging behaviour to build repeatable test campaigns for software releases, vehicle variants and production-related verification.
comframe, EVCA and BCS
Test depth and standards-aware analysis
Charging-process analysis: EVCC, BMS, OBC, signals and power
Showing decoded data is not the same as analysing the charging process. comframe can correlate protocol, low-level states, vehicle-network information and electrical behaviour. Automated Standards Analysis and Cross-Layer State Monitoring add expected context where released.
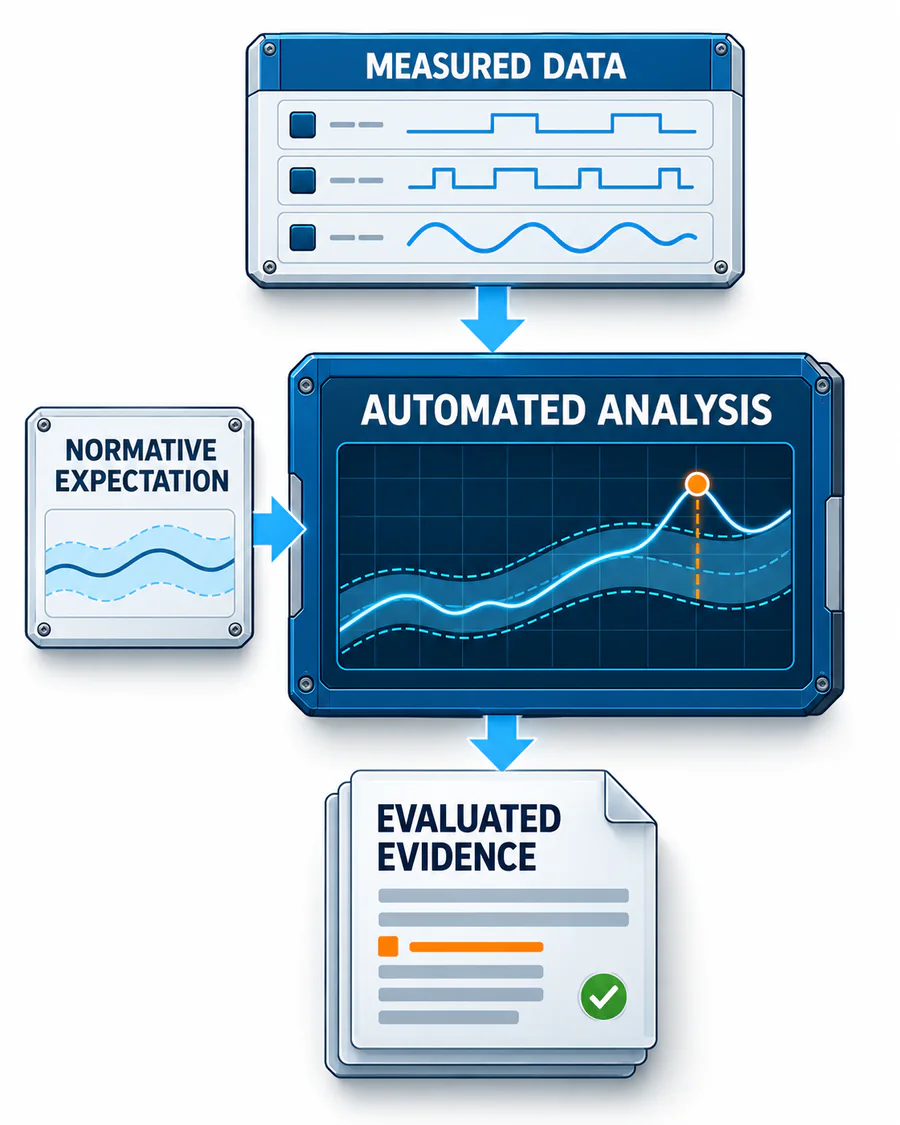 View the analysis diagram at full size
Saved configurations, unattended campaigns, reports and variant evidence.
Requests, limits, state of charge, thermal constraints and fault reactions.
Expected, optional, delayed, missing and unexpected messages.
DIN 70121, ISO 15118, certificates, TLS and timing.
Control Pilot (CP), Proximity Pilot (PP) and technology-specific connection and control states.
Voltage, current, energy transfer, contactors, isolation and controlled faults.
Cross-Layer State Monitoring is available for applicable DC CCS, CHAdeMO and DC China / GB/T DC configurations. Exact protocol versions, channels and released functions remain product-specific.
EVCA Interop and Charge Playback
Turn real charging-station behaviour into a controlled EV test.
A vehicle must work with charging-station implementations that cannot all remain in the laboratory. EVCA Interop captures the real EV-to-EVSE interaction. Charge Playback then converts supported EVSE-side PLC (power line communication) content and timing into an active physical charging partner for the EV under test.
- Real charging session
A real EV and EVSE interact under the field or interoperability condition that matters.
- Record
Capture the EVSE-side PLC content, timing and related charging measurements from the real session.
- Extract
Extract the behaviour needed for a supported EVSE simulation configuration and preserve its origin.
- Active simulation
Present the recorded charging-station behaviour actively to the EV through the physical charging interface.
- Repeat and modify
Repeat the vehicle test and vary one charging-partner condition at a time. Use the recorded vehicle response to define automated regression cases.
Replay reproduces data for the engineer.
Charge Playback reproduces charging behaviour for the device under test.
Investigate the real pair
For a real vehicle connected to a real charging station, EVCA Interop provides focused access and synchronised evidence. Choose EVCA Multi Mobile when vehicle testing also needs broader portable measurement and charging-partner simulation within the selected configuration.
Explore EVCA InteropReproduce the charging station
Use released Charge Playback functions to repeat recorded charging-station behaviour at the vehicle’s physical charging interface.
Explore Charge PlaybackGlobal charging technologies
EV charging interfaces: AC, DC CCS / NACS, CHAdeMO, GB/T and MCS
The application method remains consistent, but standards, communication, low-level signals, power hardware and released software functions differ by charging technology.
AC charging
IEC 61851-1, SAE J1772 and ISO 15118 where applicable. Test EVCC and OBC interaction with the charging-station side.
DC CCS and NACS
DIN 70121, ISO 15118-2, ISO 15118-3 and ISO 15118-20 according to the configured system and release.
CHAdeMO
CAN-based charging communication, low-level states and functional workflows for supported versions.
DC China / GB/T
GB/T 18487.1 and GB/T 27930 variants with technology-specific communication and state evaluation.
Megawatt Charging
10BASE-T1S, ISO 15118-20, CE and ID, thermal interfaces, safety and high-power validation in the dedicated MCS path.
Product pages, datasheets and Standards & Knowledge define the exact standard editions, Test Libraries, interfaces and released function scope.
From objective to implementation
EV test equipment for communication, integration and complete vehicles
EVCC and protocol development without full-power laboratory equipment.
Integrated laboratoryCommunication, low-level signals, external power, faults and automation.
Vehicle and fieldPortable simulation, measurement and multi-standard field workflows.
Megawatt ChargingDedicated MCS communication, signals, cooling and high-power architecture.
Virtual cells, sensors, balancing, isolation and fault conditions for BMS integration.
Optically isolated charging communication across the chamber boundary.
Software and evidenceConfiguration, synchronised analysis, automation, reporting and integration.
Defined test cases, standard editions, DUT roles, verdicts and evidence.
Customer references
Vehicle-side charging validation in practice.
The following customer experiences relate to testing with our EVCA systems.

Customer outcomeThe team describes EVCA as its most complete vehicle simulation, sniffer and man-in-the-middle system.
What does EVCC mean in an EV charging test?
Here, EVCC means Electric Vehicle Communication Controller: the vehicle-side charging controller that communicates with the charging station’s SECC (Supply Equipment Communication Controller). It is distinct from the separate energy-management application named evcc.
The selected boundary determines EVCA configuration, counterparts, protocol editions and signal coverage.
Frequently asked questions
EV testing
What is EV testing?
EV testing verifies how an electric vehicle, EV communication controller or charging-related vehicle subsystem behaves with a controlled simulated charging station. The vehicle side is the device under test.
What is the difference between EV testing and EVSE testing?
During EV testing, the vehicle or EVCC is the device under test and the test system simulates a charging station. During EVSE testing, the charging station is the device under test and the system simulates the vehicle.
Can an EVCC be tested before the complete vehicle exists?
Yes. A communication-focused EVSE simulator can operate an EVCC on the bench, provide the relevant charging interfaces and expose message content, timing, certificates and state transitions before full vehicle integration.
Why test EVCC, BMS and OBC together?
The EVCC negotiates charging, the BMS defines battery limits and the OBC executes AC energy conversion. Joint testing reveals inconsistent limits, states, timing and physical reactions that isolated ECU tests cannot expose.
How is direct DC charging different from AC OBC testing?
During AC charging, the onboard charger is part of the vehicle power path. During DC CCS, CHAdeMO and GB/T DC charging, the OBC is bypassed and the external charger supplies the high-voltage battery path through the vehicle inlet and contactors.
How does EVCA Interop support EV testing?
EVCA Interop captures the real interaction between a vehicle and charging station on one synchronised time base. The resulting evidence can isolate a field problem and support controlled validation or laboratory reproduction.
What is an EVCC, and what should an EVCC test verify?
The EVCC is the vehicle-side controller for charging communication with the charging station. EVCC testing checks relevant messages, state transitions and timing against a controlled station counterpart.
Integration tests also correlate its requests with BMS limits, contactor and precharge states, and the measured electrical response. AC tests include the OBC power path; direct DC charging bypasses the OBC in the energy path. The required test interfaces and functions depend on the charging technology and configured system.
Explore EVCC, BMS and OBC integration testing · Review controller communication testing
Vehicle-side test planning
Plan vehicle charging validation.
Define the vehicle or controller under test, the charging-station behaviour to simulate, operating points and acceptance criteria. Select the EVCA configuration after the test method is clear.